Posts

Showing posts with the label ESP32

BASE.001(V3) 2023 Update.

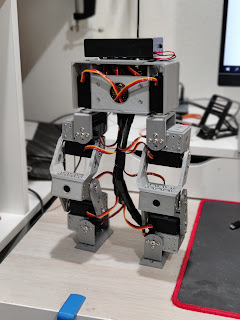
After putting BASE.001 aside for some AI fun, there is some new updates to BASE.001 (V3).  Firstly, IT WALKS! I finally took the time to replicate George Chiou's MiniPlan V5 walking gait for BASE.001. While it is still highly unstable, BASE.001 is doing what it was designed to do: to walk and experiment with gaits. Secondly, the hip is getting redesigned at the moment for some better bracing of the servos and joints. Also the connectors will be redesigned so repair would be easier to use. Currently modeling and printing the new parts, pictures in next post, hopefully! [Original post on Aug 20, 2023 7:58PM PST on Blogger]

BASE 001:End.

Image
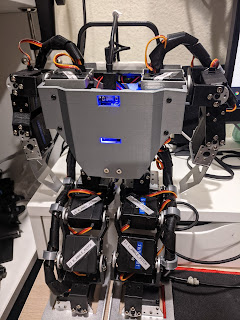
This is the end for this iteration of BASE.001 (V3), as I finally got my hands on some "smart" servos (LX-16A serial servos from Hiwonder) that I plan to use instead of these "dumb" servos. I haven't touched the code or hardware due to completing a milestone in life recently, but hopefully in 2023 I will be able to resume full attention on this project. In the meantime, here's some pictures of the robot before I tear it down and toss the parts in a drawer for who-knows-how-long. Happy belated Christmas, Happy early New Year, and see you all in the near future! Still powered by ESP32, but the inventr HERO board will be forever remembered as the first brain. #dreams2reality #r2l_bots #BASE001 [Original post on Dec 28, 2022 5:00PM PST on Facebook]

Fully Printed: V1.

Image
Ta-da! Behold, BASE.001's fully 3D printed body (V1)! It took a while, but I was able to make it work ok. The biggest issue with the model is that the hip, knee, and ankle isn't designed to bend much due to how I mounted the servos. I also rewrote the code for the ESP32's FreeRTOS; built-in tasks and non-blocking code woohoo! It haven't been able to walk though... so I will be starting over again, because certain joints are too limited, and the hip box is too big. The next leg design will be inspired by various types of humanoids such as TonyPi, Kondo HR-3, and others.  For walking, I am reading and studying the works of Dr.Guero2001 on his Kondo HR-3; Dr.GIY on his dancing robots; and WatakoLab on their custom humanoids. I will be uploading the code and the STL files to the github repo sometime in the future, please note it is very much a Work-In-Progress! [Original post on May 4, 2022 9:10PM PST on Blogger] 

Restarting, rebooting, reseting.

Image
A new year, a renewed interest in robotics! Going to resume this project, it has been sitting for too long on my shelf, waiting to be brought alive.   Currently, I am writing the code from scratch (again.) This WIP program should make everything run faster, and with less blocked code. It is very limited in functionality, calling it WIP is a understatement, maybe?  As shown in the pictures, I have labeled each servo with its port number and code name, this will help me in debugging as well as pose designing (make the robot walk, sit, etc.) Also, all servo horn brackets are now 3D printed, thus making them lighter and a bit more forgiving if the servos push too far (it will bend and recover instead of warping like the original metal brackets). Picture #2 was taken before I swapped all of the brackets; notice how the hip servos are mounted vertically instead of horizontally as with picture #1 and picture #3. Due to a project, I have been working on other 3D models and printing, t...